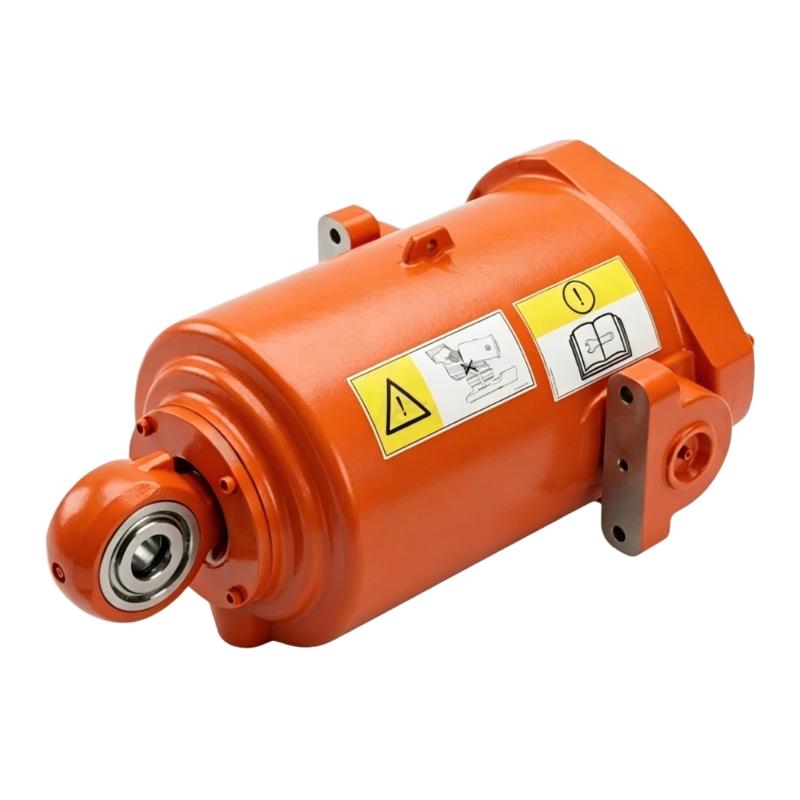
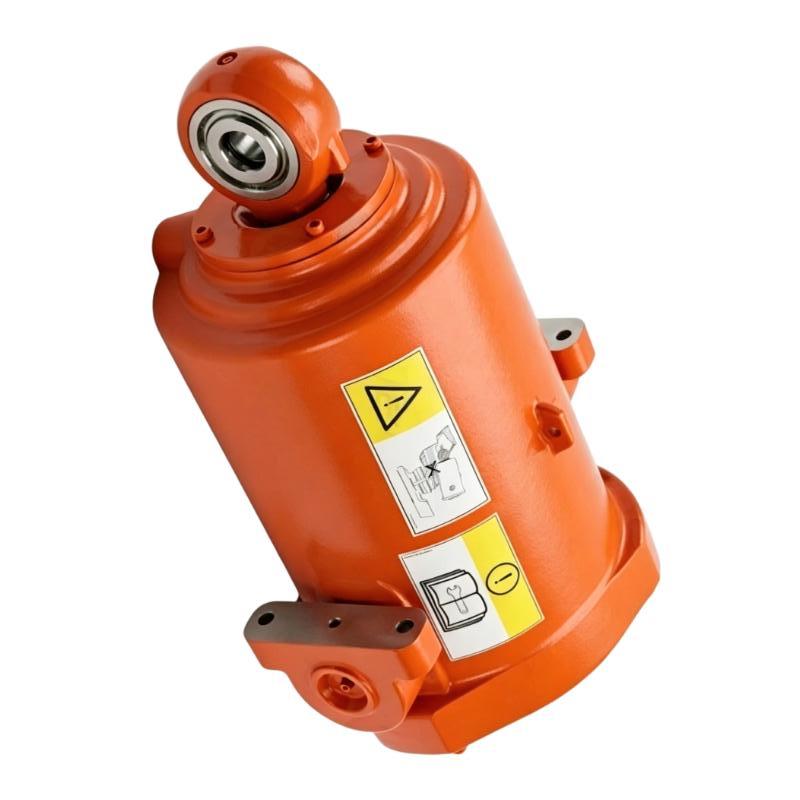
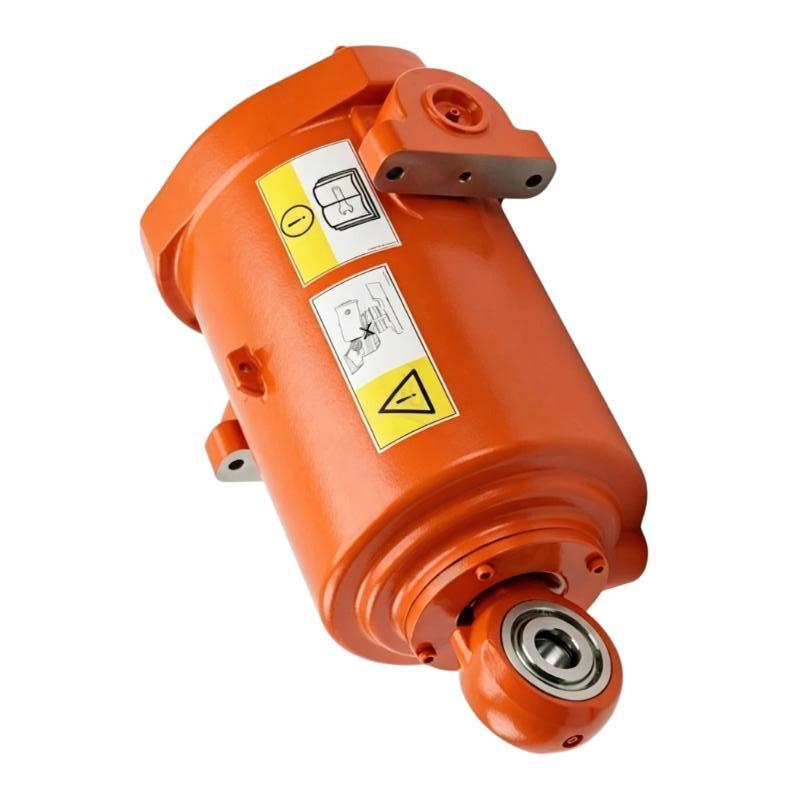
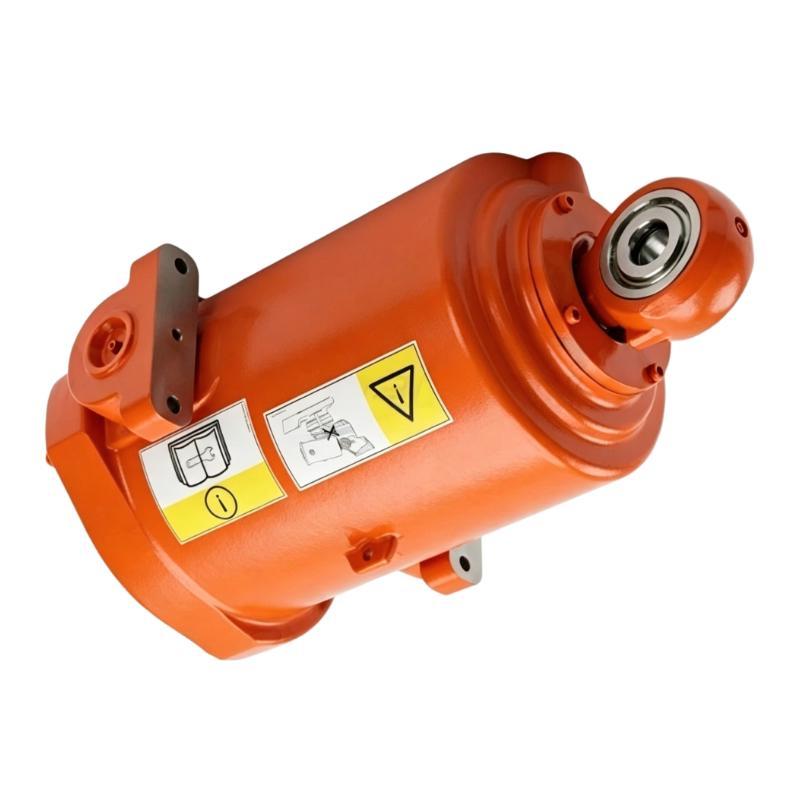
Brand:ABB PLC Item No.:3HAC14678-1 Product Origin:Sweden (SE) Product Dimensions:680 × 250 × 500 mm Product Weight:15 kg Payment:T/T, Western Union, Credit Card Goods_stock:15 Shipping Port:Xiamen, China Lead Time:1-3 Days Condition:Brand New And Original Warranty:1 Year Certificate:COO
The ABB 3HAC14678-1 Balancing Device F is a specialized mechanical spare part for ABB robotic equipment. It belongs to the mechanical side of an industrial robot system, where balancing mechanisms work alongside motors, transmissions, structural components, and axis assemblies.
Unlike electronic replacement parts, the performance of a balancing device depends heavily on its mechanical condition and correct installation. Wear, damage, incorrect mounting, or deterioration of associated components can influence the way forces are distributed through the robot arm.
For maintenance departments, the value of the 3HAC14678-1 lies in its role within the overall robot architecture. Maintaining the mechanical balancing system can contribute to smoother robot operation and help protect the associated drive and transmission system from unnecessary mechanical stress.
The part is particularly relevant to plants operating established ABB IRB 6600 installations where maintaining the original mechanical design is preferable to introducing an unverified substitute.
For buyers sourcing industrial robot spare parts, the complete designation 3HAC14678-1 should be used when checking compatibility, quotation details, inventory records, and maintenance requirements.
Technical Specifications and Product Data
Parameter
Specification
Brand
ABB
Part Number
3HAC14678-1
Product Type
Balancing Device
Device Designation
Balancing Device F
Equipment Category
Industrial Robot Mechanical Component
Associated Robot Family
ABB IRB 6600
Application
Robot Arm Mechanical Balancing
Component Type
Mechanical Spare Part
Dimensions
680 × 250 × 500 mm
Weight
15.00 kg (33.07 lb)
Installation
Robot Mechanical Assembly
Primary Function
Mechanical force balancing
Maintenance Role
Replacement / service component
The listed dimensions and weight are provided for product identification and procurement planning. Before installation, the complete robot configuration and applicable mechanical documentation should be checked to ensure the selected part corresponds to the intended assembly.
Recommended Related Models
The following ABB parts are relevant when maintaining or repairing an ABB IRB 6600 mechanical system:
Model
Product Description
Relationship
ABB 3HAC14675-1
Balancing Device E
Related balancing device
ABB 3HAC14673-3
Rotational AC Motor M3
Related robot motor component
ABB 3HAC14673-6
Rotational AC Motor M6
Related robot motor component
ABB 3HAC14673-8
Rotational AC Motor M8
Related robot motor component
ABB 3HAC14673-9
Rotational AC Motor M9
Related robot motor component
ABB 3HAC14673-10
Rotational AC Motor M10
Related robot motor component
ABB 3HAC14638-1
Cable Conduit
Related mechanical installation component
ABB 3HAC14624-1
Bracket for Cable Clamp
Related mechanical component
These parts should not be treated as automatic substitutes for one another. Their suitability depends on the specific robot model, axis configuration, and mechanical assembly.
Popular Related Models for ABB Robot Maintenance
Model
Product Description
Typical Maintenance Relevance
ABB 3HAC020691-001
Replacement Balancing Device
Replacement option associated with the balancing-device assembly
ABB 3HAC17117-2
Related Counter Balance Assembly
Associated mechanical balancing application
ABB 3HAC14675-1
Balancing Device E
Alternative balancing-device designation
ABB 3HAC14673-3
Rotational AC Motor M3
Robot axis drive component
ABB 3HAC14673-6
Rotational AC Motor M6
Robot axis drive component
ABB 3HAC14673-8
Rotational AC Motor M8
Robot axis drive component
ABB 3HAC14673-9
Rotational AC Motor M9
Robot axis drive component
ABB 3HAC14673-10
Rotational AC Motor M10
Robot axis drive component
For spare-parts purchasing, 3HAC14678-1 should remain the primary identification number. Related models are useful for building a broader maintenance inventory around the ABB IRB 6600 robotic platform.
Applications and Robot Integration
The ABB 3HAC14678-1 Balancing Device F is a mechanical balancing component associated with ABB industrial robot systems, particularly the IRB 6600 robot family. Its primary role is to support the mechanical balance of the robot arm, helping maintain stable movement and reducing the load that would otherwise be imposed on the robot's drive and mechanical transmission components.
In demanding robotic applications, mechanical balance is important because the robot must repeatedly accelerate, decelerate, stop, and reverse while carrying process equipment or a payload. A correctly functioning balancing device contributes to smoother axis behavior and helps the robot maintain predictable mechanical performance.
The 3HAC14678-1 can be considered for applications such as:
Robotic material handling
Automotive production lines
Welding and fabrication systems
Machine tending
Heavy-duty robotic manipulation
Automated assembly
Industrial material transfer
Replacement and maintenance of ABB IRB 6600 mechanical assemblies
For maintenance teams working with older ABB robotic installations, selecting the correct mechanical spare part is particularly important. A properly matched balancing component can help restore the intended mechanical configuration without unnecessary modifications to the robot.
Key Advantages for Industrial Maintenance
Designed for ABB robotic mechanical systems
The 3HAC14678-1 is identified as a Balancing Device F, making it a purpose-specific mechanical component rather than a general-purpose balancing mechanism.
Supports stable robot movement
A functioning balancing assembly helps manage mechanical forces within the robot arm. This is particularly valuable when the robot operates with substantial arm movement or payload-related loading.
Suitable for maintenance and replacement work
For facilities maintaining existing ABB IRB 6600 equipment, using a correctly identified spare part can simplify maintenance planning and reduce the risk associated with mechanical substitutions.
Helps preserve the original mechanical configuration
Replacing a worn or damaged balancing component with the appropriate part helps maintenance engineers retain the intended robot architecture and mechanical relationships.
A practical choice for long-service robotic equipment
Industrial robots often remain in production for many years. Mechanical spare parts such as balancing devices can therefore be important when restoring older production cells and extending their operational service life.
Useful for professional spare-parts procurement
The complete part number 3HAC14678-1 provides a clear identification point for purchasing, inventory management, maintenance planning, and replacement activities.
Technical FAQs: Engineering Questions and Answers
1. What is the ABB 3HAC14678-1 used for?
The 3HAC14678-1 is a mechanical Balancing Device F used in ABB robotic equipment. It is associated with the mechanical balancing arrangement of the robot arm and helps manage forces acting on the robot structure during operation.
2. Which ABB robot is associated with the 3HAC14678-1?
The part is associated with the ABB IRB 6600 robot family. Engineers should verify the exact robot variant and mechanical configuration before ordering a replacement.
3. Is the 3HAC14678-1 an electrical or electronic module?
No. It is a mechanical robot component. It does not function as a PLC module, drive, controller, I/O module, or communication unit.
4. What symptoms may indicate a problem with a robot balancing device?
Potential indications include abnormal mechanical movement, unusual loading on an axis, unexpected arm behavior, mechanical noise, increased vibration, or difficulty maintaining normal robot motion. A complete mechanical inspection should be performed before identifying the balancing device as the cause.
5. Can the balancing device be replaced during robot maintenance?
Yes, replacement is part of mechanical maintenance when the component has been damaged, excessively worn, or otherwise determined to require replacement. The robot should be placed in a safe maintenance condition and appropriate lifting and mechanical-support procedures should be followed.
6. Does a balancing device affect robot axis performance?
It can. The balancing mechanism forms part of the robot's mechanical load-management system. If its mechanical condition changes significantly, the loads experienced by associated mechanisms can also change.
7. Should robot calibration be checked after replacing the balancing device?
The mechanical replacement itself does not automatically mean that calibration data must be changed. However, the robot should be inspected and tested after maintenance, and calibration or mechanical mastering should be verified if the replacement procedure or associated mechanical work could have affected the robot's axis geometry or reference position.
8. What should be checked before installing a replacement 3HAC14678-1?
Maintenance personnel should verify the complete part number, robot model, mechanical configuration, mounting interfaces, condition of related hardware, and the installation procedure applicable to the specific robot.
9. What can happen if an incorrect balancing component is installed?
An incorrectly matched component can alter the mechanical characteristics of the robot arm and may result in abnormal loading, poor motion behavior, accelerated wear, or unsafe operating conditions. Part-number verification is therefore essential.
10. Is the 3HAC14678-1 suitable as a general replacement for every ABB balancing device?
No. Balancing devices are application-specific mechanical components. The 3HAC14678-1 should be selected only when the robot configuration and spare-part identification confirm compatibility.